


Fictionlab Leo Rover Vision Pack v1.9
- SKU: MBS-Z-411
- GTIN: 0658917504793
- Category: Accesoires
-
Manufacturers:

Leo Rover Vision Pack v1.9
- Up to 40 TOPS
- 7-15 W
- Compatible with: TensorFlow, PyTorch, ROS 1/2
Description
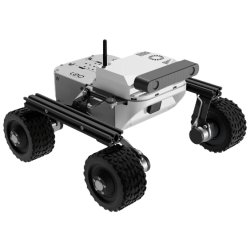
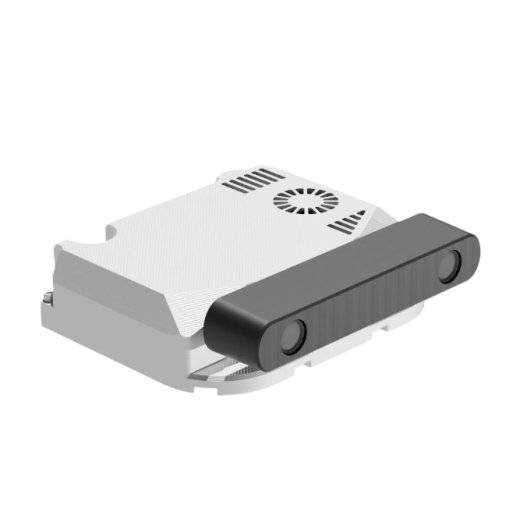
The Vision Pack is a compact, powerful add-on that gives your Leo Rover real artificial intelligence and advanced computer-vision capabilities. At its core is the NVIDIA Jetson Orin Nano – a modern AI platform with up to 40 TOPS of compute power – combined with the Stereolabs ZED 2i stereo camera (version with non-polarized lenses).
The ZED 2i delivers crisp RGB images and precise depth information up to 20 metres away. Thanks to the wide 110° field of view and integrated sensors – IMU, barometer and magnetometer – it enables excellent spatial perception and environmental analysis. Combined with the AI power of the Orin Nano, demanding tasks such as SLAM, object detection, semantic segmentation or obstacle avoidance are processed in real time directly on board – with no cloud dependency.
Key upgrades
- Unified enclosure: the compute unit (NVIDIA Jetson) and the ZED camera mount are combined into a single body.
- Plug-and-play: connects directly via the external USB-C port – a modified developer cover is no longer required.
- Open rear chassis: the entire rear section of the rover stays clear, so multiple sensors and custom payloads can be mounted simultaneously and without hardware interference.
Technical specifications
| Compute unit | NVIDIA Jetson Orin Nano with 8-core CPU and Ampere GPU (1024 CUDA cores, 32 Tensor Cores) |
| AI performance | Up to 40 TOPS |
| Power consumption | 7 – 15 W (configurable) |
| Supported frameworks | TensorFlow, PyTorch, ROS 1 / 2 |
| Stereo camera | Stereolabs ZED 2i (non-polarized lenses) |
| Depth range | Up to 20 m |
| RGB resolution | Up to 2K |
| Integrated sensors | IMU, barometer, magnetometer |
| Field of view | 110° (horizontal) |
| Connection | USB-C (external, plug-and-play); USB 3.0 (camera) / Ethernet, USB 3.2 (Orin Nano) |
| Compatibility | ROS 1 / 2, ZED SDK, JetPack SDK |
Typical applications
- Visual SLAM and 3D mapping
- Autonomous obstacle detection and navigation
- Environment recognition through AI-based image processing
- Real-time perception on mobile robotics platforms
Reviews
There are no reviews yet.

