


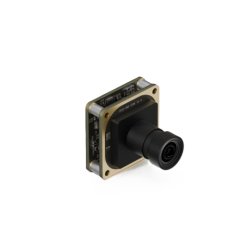


Stereolabs ZED X One Core
- SKU: MBS-SES-438
- Category: 3D Machine Vision
-
Manufacturers:
Stereolabs ZED X One
- Smallest possible footprint: barebone module from 27 × 27 × 29.7 mm and 14 g – for direct OEM integration
- Global shutter in Full HD: 2.3 MP with 1920 × 1200 at 60 fps, distortion-free under fast motion
- Native MIPI I-PEX interface: cable runs up to 70 cm, up to four synchronised cameras per capture card Core
- Versions: no lens, Narrow, Wide, Fisheye
Description
Stereolabs ZED X One Core – Monocular Camera for OEM Integration
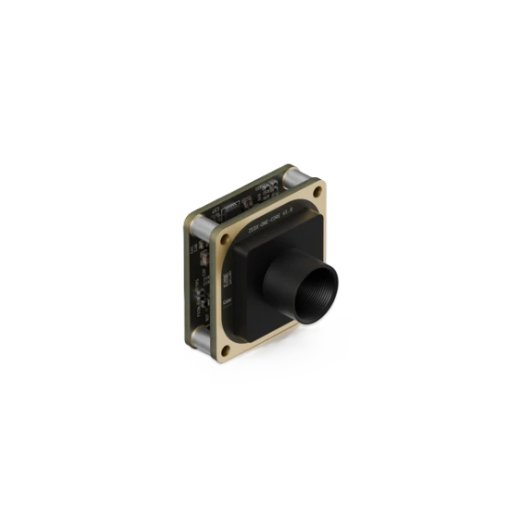
The ZED X One Core is a barebone camera module for manufacturers who want to build industrial machine vision directly into their own device. Without a housing of its own it measures just 27 × 27 mm at the base and weighs 14 to 19 g depending on the lens – so it fits where a ready-made camera no longer finds room: in humanoid heads, robot wrists, end effectors and compact sensor units.
Connection is made via a native industrial MIPI I-PEX interface. It supports coaxial cable lengths of up to 70 cm and therefore offers considerably more freedom in cable routing inside the enclosure than conventional MIPI connections.
Your advantages at a glance
- Smallest possible footprint: barebone module from 27 × 27 × 29.7 mm and 14 g – for designs where every millimetre counts
- Global shutter in Full HD: 2.3 MP sensor with 1920 × 1200 at 60 fps – distortion-free capture of fast-moving objects
- Three lens options: fisheye, wide and narrow – also available without a lens for your own optics
- Integrated IMU: BOSCH BMI088 with 16-bit accelerometer and gyroscope, vibration-resistant and temperature-stable
- Multi-camera synchronisation: frame-level hardware sync within microseconds, up to four cameras per capture card
- Low power draw: powered via MIPI with a maximum of 240 mA at 5 V
Important note on system requirements
The ZED X One Core is designed exclusively for operation with the ZED Link MIPI capture card (ACC-213000) and is not compatible with GMSL2 or USB setups. The card connects directly to the NVIDIA Jetson AGX Orin Developer Kit, or via the NVIDIA Holoscan Sensor Bridge to the Jetson AGX Thor Developer Kit. Lens focusing and calibration – intrinsic as well as extrinsic for stereo setups – are carried out by you as the integrator.
Typical applications
- Humanoid robots with all-round vision and SLAM
- Robot arms and grippers with the camera mounted directly on the wrist
- Custom sensor modules in series production
- Data collection and teleoperation
- Surround-view systems with several synchronised cameras
Technical data
| Sensor type | 1/2.6" 2.3 MP CMOS, global shutter |
| Array / pixel size | 1928 × 1208 pixels, 3 µm × 3 µm |
| Resolution | 1920 × 1200 @60 fps, 1920 × 1080 @60 fps (crop), 960 × 600 @120 fps (binning) |
| Output format | RAW10 (v4l2) / NV21 (Argus) |
| Signal-to-noise ratio | 38 dB, dynamic range 71.4 dB |
| Field of view Fisheye | 195° (H) × 115° (V) × 220° (D), focal length 1.38 mm, f/2.0 |
| Field of view Wide | 110° (H) × 80° (V) × 120° (D), focal length 2.2 mm, f/2.2 |
| Field of view Narrow | 80° (H) × 52° (V) × 91° (D), focal length 3.8 mm, f/1.8 |
| IMU | BOSCH BMI088, 6-axis, ±12 g / ±1000 dps, 400 Hz |
| Interface | MIPI via micro I-PEX cable, up to 70 cm |
| Dimensions | 27 × 27 × 29.72 mm (fisheye), 34.52 mm (wide), 33.61 mm (narrow) |
| Weight | 17 g (fisheye), 19 g (wide), 14 g (narrow) |
| Mounting | 4 holes, 2.2 mm diameter |
| Power consumption | max. 240 mA at 5 V DC, powered via MIPI |
| Operating temperature | -20 °C to +60 °C |
| System requirements | NVIDIA Jetson, Jetson Linux (L4T) v35.1 or newer, ZED Link MIPI capture card |
| Warranty | 2 years |
Matching accessories
- ZED Link MIPI Quad capture card (ACC-213000) – mandatory
- Enclosure for Orin AGX Developer Kit (ACC-221000)
Scope of delivery
- 1× ZED X One Core
- 1× MIPI I-PEX cable
Reviews
There are no reviews yet.

