


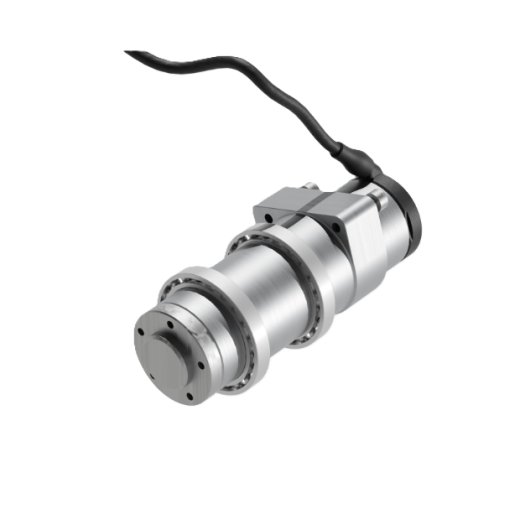
Fictionlab Leo Rover Omnidirectional Wheel Module
- SKU: MBS-Z1-103
- GTIN: 0658917510756
- Category: Accessories
-
Manufacturers:

Fictionlab Leo Rover Omnidirectional Wheel Module
- Proven drive unit from the Leo Rover v. 1.8 and v. 1.9 — available as an individual component for your own platforms
- 1 Nm at 40 rpm via a three-stage planetary gearbox (73.1:1), with magnetic encoder
- IP66 protection — sealed for outdoor use
Description
The Fictionlab wheel module is the drive unit fitted in the current Leo Rovers, versions 1.8 and 1.9. Available as an individual component, the proven design can be adopted for your own vehicle concepts – without having to purchase a complete rover.
At its core is a 12 V DC motor with a magnetic encoder and a three-stage planetary gearbox with a 73.1:1 ratio. This yields 1 Nm of torque at a rated speed of 40 rpm – designed for continuous operation of a mobile platform in the field.
Hub, motor tube and wheel mounts are CNC-machined and guided by two ball bearings. All-round rubber seals bring the module to IP66 protection, so that dust and jets of water cannot harm the drive. A 55 cm six-wire cable comes pre-assembled: four wires for the encoder, two for the power supply.
You have a choice of connector: six goldpins for freely building your own electronics, or the dedicated LeoCore connector if the module is intended as a replacement part in an existing Leo Rover. The version is requested when you place the order.
Applications
- Replacement part for Leo Rover v. 1.8 and v. 1.9
- Building your own mobile robot platforms and research vehicles
- Prototyping in outdoor robotics
- Teaching and student projects using proven drive technology
Highlights
- Proven drive unit from the Leo Rover v. 1.8 and v. 1.9
- 1 Nm at 40 rpm via a three-stage planetary gearbox (73.1:1)
- Magnetic encoder with 12 CPR for speed and position feedback
- IP66 protection thanks to all-round rubber seals
- CNC-machined components and two ball bearings
- Pre-assembled 55 cm cable with six wires
- Two connector versions: goldpin for your own developments or LeoCore for replacement use
Technical Data
| Product | Fictionlab wheel module (Rover Wheel v. 2.0) |
| Motor | 12 V DC motor |
| Encoder | Magnetic encoder, 12 CPR |
| Torque | 1 Nm |
| Rated speed | 40 rpm |
| Gearbox | Three-stage planetary gearbox, ratio 73.1:1 |
| Mechanics | CNC-machined hub, motor tube and wheel mounts, 2 ball bearings |
| Connecting cable | 55 cm, 6-wire (4 × encoder, 2 × power supply) |
| Connector versions | 6 × goldpin or LeoCore connector (selectable when ordering) |
| Ingress protection | IP66 (sealed with rubber seals) |
| Compatibility | Leo Rover v. 1.8 and v. 1.9 |
Scope of Delivery
- 1 × Wheel module with motor, gearbox, encoder and pre-assembled cable
Important note: A wheel (rim and tyre) is not included.
Reviews
There are no reviews yet.


