


Foxtech ExoArm-7 Wearable Exoskeleton Teleoperation Kit
- SKU: MBS-ROB-94
- GTIN: 0658917505097
- Category: Robot Arms
- Manufacturers:
Foxtech ExoArm-7 Wearable Exoskeleton Teleoperation Kit
- Wearable leader arm (exoskeleton) with 14 degrees of freedom (7 per arm)
- 14-bit absolute encoders, joint data up to 1000 Hz, latency < 20 ms
- USB Type-C, Python SDK and ROS 2 demo, compatible with OpenArm
- Integrated by MYBOTSHOP into our humanoids, every joint value freely accessible
Description
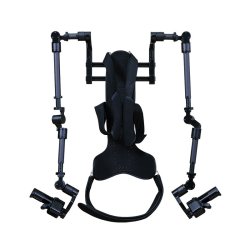
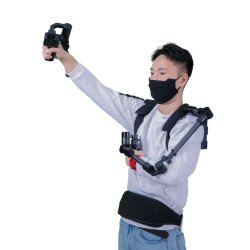
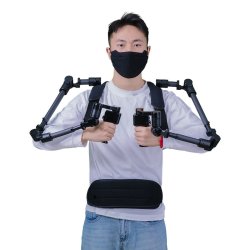
The Foxtech ExoArm-7 is a wearable exoskeleton for teleoperating robotic arms and collecting human demonstration data. The lightweight, ergonomically optimised system maps every arm movement of the operator directly to the robot with a latency below 20 ms – for smooth, natural and responsive control. It serves as a leader arm for leader-follower teleoperation – the robot arm (follower, e.g. OpenArm) mirrors the operator’s movements.
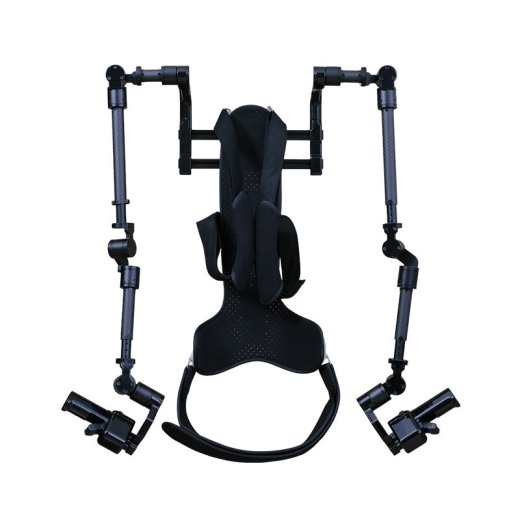
At its core are high-precision joint modules with 14-bit absolute encoders and a sampling rate of up to 1000 Hz. Telescopic carbon fibre links, shoulder straps and an ergonomic back system keep it comfortable even during long sessions. Paired with robotic arms such as OpenArm, it produces high-quality datasets for imitation learning, reinforcement learning and VLA (Vision-Language-Action) models.
Key Features
- High-precision motion capture: 14-bit single-turn absolute encoders for stable position feedback
- Natural control: 7 degrees of freedom per arm (14 in total) in an anthropomorphic configuration
- Low latency: < 20 ms from arm movement to robot, joint data up to 1000 Hz
- Two handles with linear trigger, TMR dual-axis joystick, 4 custom buttons and toggle switch
- Optional IMUs for back (torso posture) and head (head posture)
- Lightweight and ergonomic: approx. 3 kg (excluding back system), arm length adjustable via telescopic carbon links
- Wide compatibility: supports multiple robotic arm models including OpenArm; integration via SDK
Integration by MYBOTSHOP
MYBOTSHOP integrates the ExoArm-7 into any humanoid we sell. See it in action in our demo video with the Unitree H2: the operator directly guides both arms and hands of the robot – the H2 lifts a bin off a table and places it into a box.
- Every joint value is freely accessible – no black box, the data is available for your own applications, recording and training
- The joysticks and buttons on the handles can be freely mapped: for example, steer the robot and make it walk with the joystick while still guiding its arms
- The triggers can operate grippers or robot hands
ExoArm-7 or VR headset?
For quick, lightweight demos a VR headset is the better choice: put on in seconds and ready to use without fitting it to the operator.
The ExoArm-7 shows its strengths when the joints themselves must be mapped accurately to the real robot. Every joint is captured individually and can be guided precisely – not just the position of the hand. This helps wherever arm posture matters, e.g. when grasping inside containers, shelves or machines.
Software & Integration
- Host software (Chinese/English) for device management, real-time statistics, button mapping and firmware updates
- Forwarding of exoskeleton data via WebSocket to the robot controller
- Python SDK and CLI (serial over USB, Windows/Linux/macOS, MIT licence)
- ROS 2 demo workspace: WebSocket receiver, RViz visualisation, retargeting template for your own robot, recording and replay
Applications
- Teleoperation of robotic arms and dual-arm systems
- Data acquisition for imitation learning, reinforcement learning and VLA models
- Research, teaching and robotics courses at universities and institutes
- Integration into VR/AR systems for immersive control and simulation
Technical Data
| Degrees of freedom | 14 (7 per arm); 10 free and 4 lockable rotary joints |
| Configuration | Anthropomorphic, two arms with back system |
| Mechanical joint ranges | J1: 270°, J2: 240°, J3/J5: 300°, J4/J6/J7: 180° |
| Encoder resolution | 14 bit (absolute encoders) |
| Joint data rate | up to 1000 Hz |
| Joystick/trigger data | max. 200 Hz (filtered) |
| Latency | < 20 ms |
| Links | Carbon fibre, telescopic, adjustable |
| Fixation | Shoulder straps, ergonomic back system, waist belt |
| Weight | approx. 3 kg (excluding back system), joint module approx. 60 g |
| Power supply | USB Type-C PD, 5 V |
| Data interface | USB Type-C |
| Handles | 2 (linear trigger, TMR dual-axis joystick, joystick press, 4 custom buttons, side toggle switch) |
| Sensors (optional) | 1 × back IMU, 1 × head IMU |
| Software | Host software, Python SDK, ROS 2 demo |
Scope of delivery
- 1 × ExoArm-7 exoskeleton teleoperation system (two arms with handles and back system)
Image may differ.
| Item information | Value |
|---|---|
| Shipping weight: | 23,00 kg |
Reviews
There are no reviews yet.

