


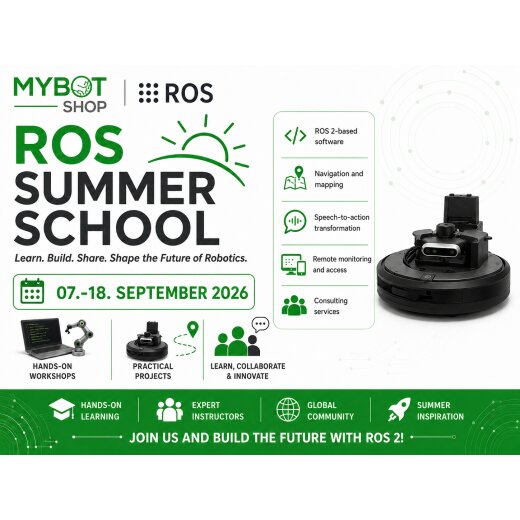
ROS Summer School
- SKU: MBS-SE-07
- GTIN: 0658917504939
- Category: Pupils & Schools
ROS Summer School
- 07.–18. September 2026 (2 weeks)
Description
The ROS Summer School at FH Aachen (Faculty of Mechanical Engineering and Mechatronics) is a two-week, hands-on intensive course centered on ROS (Robot Operating System) and mobile autonomous robotics. Since 2012 it has offered students and researchers the ideal starter package to get into ROS from scratch or deepen existing skills – together with suitable robot hardware and the open-source middleware ROS.
After a few introductory courses, the summer school addresses the core topics of mobile robotics: perception, localization, mapping (SLAM) and path planning. True to the motto "learning by doing", all topics are practiced in small groups on real mobile robots. The teaching material has been updated to ROS2 and uses current packages such as Nav2 to navigate the TurtleBots through the arena.
The highlight is a competition (Urban Challenge) at the end: in teams, participants design a typical mobile robot application on identical hardware. The program is rounded off with leisure activities such as a guided tour through Aachen, barbecues and excursions (incl. Cologne, Maastricht, Paris). The event is supported by the ROSIN project of the European Commission.
Key facts
| Event | ROS Summer School 2026 |
| Organizer | FH Aachen, Faculty of Mechanical Engineering and Mechatronics |
| Period | 7–18 September 2026 (2 weeks) |
| Location | Aachen, Germany |
| Language | English |
| Credits | 4 ECTS (external participants only); optional written exam with ROS certificate and grade |
| Target group | students and staff of educational or research institutions (non-profit event) |
| Requirements | basic knowledge of C++ or Python recommended; ROS/Linux experience not required |
| Equipment | a computer is provided (no personal laptop needed) |
| Registration / deadline | registration via eveeno.com/ros-26; application deadline 31 August 2026 |
Topics
Introduction to mobile Robotics
- ROS2 file system & ROS2 communication
- Hardware and sensors, ROSSerial
- Transformations in ROS2
- Image processing with OpenCV & ROS; AprilTag detection
- Landmark detection
- Localization, mapping and SLAM
- Path planning (Nav2)
- GAZEBO Simulator
- Final competition (Urban Challenge)
Note: Costs for accommodation, meals and day trips are not included in the participation fee. Participants need valid health, liability and accident insurance. Registration is only valid after timely payment; payment by bank transfer in euros only.
Reviews
There are no reviews yet.

