


Robotis Hand HX5
- SKU: MBS-G-27
- Category: Gripper
-
Manufacturers:
Robotis Hand HX5
- 20 Degrees of Freedom (DoF)
- Integrated tactile sensors
- DYNAMIXEL smart actuators
Description
ROBOTIS HX5-D20 Robotic Hand
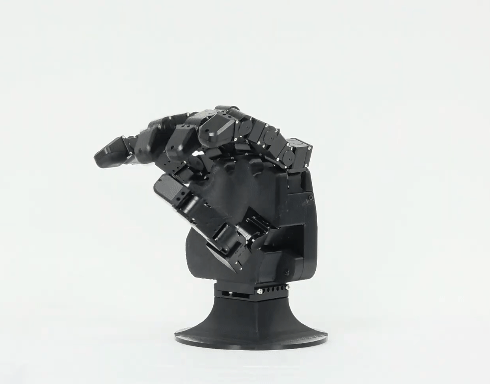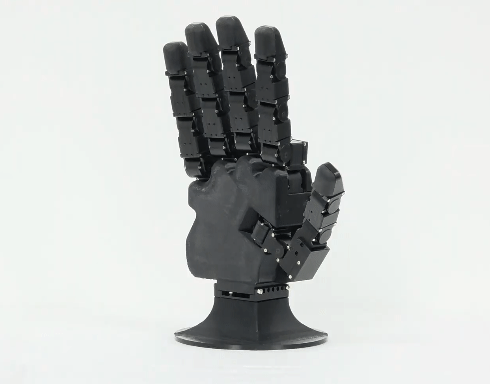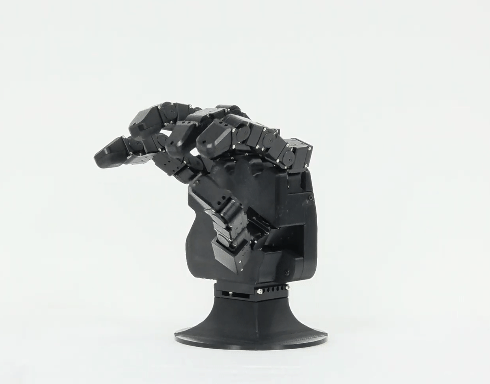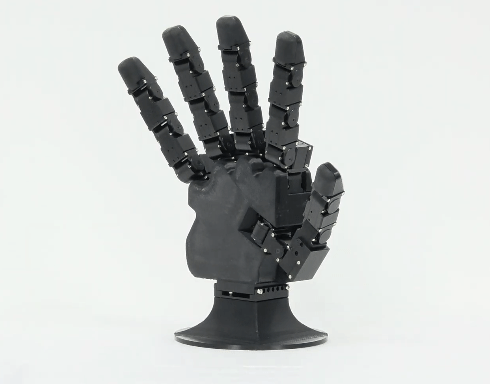
The ROBOTIS HX5-D20 is an advanced multi-jointed robotic hand with 20 degrees of freedom, specifically designed for precise and versatile manipulation tasks in robotics. Thanks to its biomimetic design, it realistically replicates the movements of a human hand and enables complex grasping patterns as well as delicate interaction with a wide variety of objects. Each finger features multiple joints, allowing both powerful and highly precise movements.
The integration of DYNAMIXEL smart actuators ensures accurate control of position, speed, and torque. In addition, tactile sensors are embedded in the fingertips to detect contact and pressure, enabling adaptive gripping control. This improves safety when handling sensitive objects and increases efficiency in automated processes.
Technical Data
- Degrees of Freedom: 20 DoF (4 per finger)
- Number of Fingers: 5
- Dimensions: approx. 243 × 128 × 65 mm
- Weight: approx. 970 g
- Operating Voltage: 24 V DC
- Max. Finger Force: 14 N
- Max. Payload (grasp envelope): approx. 15 kg
- Sensors: Tactile sensors in fingertips
- Actuators: XM335-T323-T DYNAMIXEL
- Communication: RS-485 (up to 4 Mbps)
- Control Frequency: up to 1000 Hz
- Material: Aluminum
- Software: ROS 2 compatible (ros2_control)
Scope of Delivery
- 1 × ROBOTIS HX5-D20 Robotic Hand (pre-assembled)
- 1 × FRP42_41U-K Module
- 1 × Cable 180 mm
- 1 × Cable 300 mm
- 3 × Connection Cables (various lengths)
- 20 × M3×8 Screws
Note: Power supply, U2D2 interface, and additional accessories may be required depending on the application.
Reviews
There are no reviews yet.

