


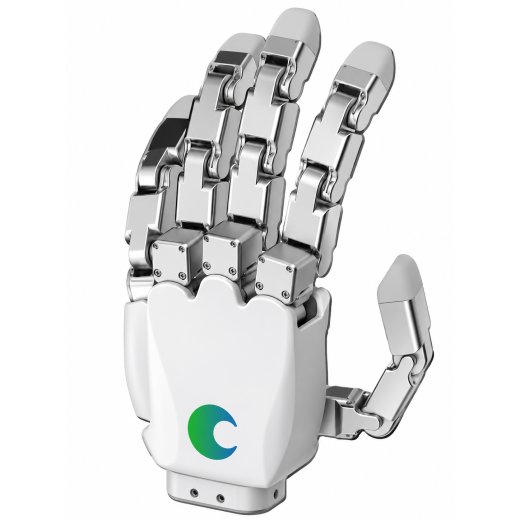
Tesollo Delto Gripper 5 Finger S (DG-5F-S)
- SKU: MBS-G-59
- HAN: DG-5F-S
- Category: Gripper
-
Manufacturers:

Tesollo Delto Gripper 5 Finger S (DG-5F-S)
- 20 degrees of freedom, 4 per finger
- Ethernet & Modbus TCP, ROS 2 support
- Weighs just 880 g and is the size of an adult’s hand
Description
The Tesollo Delto Gripper DG-5F-S is the compact version of the proven DG-5F: an anthropomorphic robotic hand with 20 degrees of freedom, the size of an adult hand – and weighing just 880 g. This makes it particularly well suited to humanoid robots where weight and space at the wrist are limited.
Each of the 20 joints is driven by its own integrated actuator – with no mechanical coupling. All fingers and phalanges can be controlled independently of one another, enabling complex grasping and manipulation tasks, from tool use to precision assembly. The low-backlash drive technology ensures accurate and stable positioning.
Compared with the larger DG-5F, the S version offers roughly half the mass at significantly lower cost, while remaining strong enough for objects of up to 12 kg in an enveloping grasp.
Ideal for:
- Humanoid robots and mobile manipulators
- Grasping and manipulation research, embodied AI and imitation learning
- Robotic tool use
- Handling unstructured objects of different shapes and materials
- Precision assembly and fastening tasks
Key Benefits
- 20 degrees of freedom, 4 per finger, each joint with its own actuator
- Only 880 g in the size of an adult hand
- Low-backlash drives with absolute encoders for precise positioning
- Built-in grasping and manipulation algorithms for a wide range of objects
- Ethernet (TCP/IP) and Modbus TCP with 500 Hz control frequency
- SDK and ROS 2 integration incl. ros2_control, MoveIt 2, Gazebo and RViz
- Robot models available as URDF, USD and XML, plus 3D models (STEP)
- Optionally available with tactile fingertip sensors or as a compact 15-DoF version
The ideal choice for anyone seeking human-like dexterity in a lightweight hand built for humanoids.
DG-5F vs. DG-5F-S
| Parameter | DG-5F | DG-5F-S |
|---|---|---|
| Weight | 1.76 kg | 0.88 kg |
| Size | larger than a human hand | adult-hand size |
| Degrees of freedom | 20 (4 per finger) | 20 (4 per finger) |
| Pinching payload (rated/max.) | 2.5 / 5 kg | 1 / 2 kg |
| Enveloping payload (rated/max.) | 10 / 20 kg | 7 / 12 kg |
| Voltage / max. current | 24 V DC / 10 A | 24 V DC / 10 A |
| Communication | Ethernet (TCP/IP), Modbus RTU/TCP | Ethernet (TCP/IP), Modbus TCP |
Technical Specifications
| General | |
| Design | Anthropomorphic five-finger hand |
| Degrees of freedom | 20 (4 per finger), each joint individually actuated |
| Weight | 880 g |
| Size | Adult-hand size |
| Performance | |
| Pinching payload | 1 kg rated / 2 kg max. |
| Enveloping payload | 7 kg rated / 12 kg max. |
| Note | Payload depends on the friction of the object |
| Electrical | |
| Input voltage | 24 V DC |
| Max. current consumption | 10 A |
| Communication | Ethernet (TCP/IP), Modbus TCP |
| Control | |
| Control frequency | 500 Hz |
| Encoder | Absolute encoder |
| Software | DGManager, SDK (Linux x86_64), ROS 2 (ros2_control, MoveIt 2, Gazebo, RViz) |
| Models | URDF, USD, XML, STEP |
| Options | |
| Tactile sensing | Fingertip sensors for contact detection |
| Compact version | Five fingers with 15 degrees of freedom |
Scope of Delivery
- 1× 5-finger DELTO GRIPPER-S
- 1× gripper cable
- 1× Ethernet cable (3 m)
- 1× bolt set
- 1× adapter frame
- 1× 4 GB USB stick (sample programs)
| Item information | Value |
|---|---|
| Shipping weight: | 1,30 kg |
| Item weight: | 0,88 kg |
Reviews
There are no reviews yet.

