




Trossen Robotics Workbench
- SKU: MBS-TR-23
- Category: Robot Arms
-
Manufacturers:

Trossen Robotics Workbench
- WidowX Arme
- Jetson Orin AGX 64GB
- ZED X Kameras
Description
Trossen Workbench – portable bimanual robot station for Physical AI
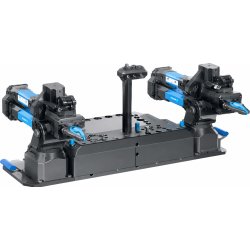
The Trossen Workbench is a portable, standardized station with two WidowX follower arms. It covers the entire Physical AI workflow: data collection, training, evaluation and deployment – with the same arms, the same software and the same workflows at every stage.
Both arms and the scene camera are mounted on a shared, machined metal plate with integrated handles. The arms are bolted in fixed positions, so the distance between them stays exactly the same even after relocation. The scene camera is mounted on a post at a defined height and angle – so the viewpoint remains identical across multiple Workbench stations.
Computer, power distribution and networking are permanently installed on the station. To relocate it, the entire station is lifted, clamped onto a new table and put back into operation with a single calibration routine – without removing the arms, re-measuring distances or rewiring.
Versions
The Workbench is available in two configuration levels, each with three arm variants. Both arms of a station are identical.
- Workbench: The fully integrated station with two WidowX follower arms, onboard computer, power supply, networking and user interface.
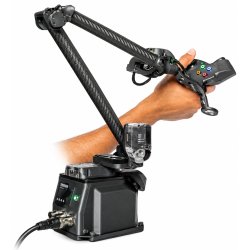
- Workbench Complete: Like the Workbench, plus a Glide leader arm pair (left and right) and the Cockpit operator station – ready for teleoperated data collection right away, including remotely via Trossen Cloud.
| Version | Arms (2×) | Payload per arm | Onboard computer | Glide (pair) | Cockpit | Cameras |
|---|---|---|---|---|---|---|
| Workbench + Core | WidowX Core | 2 kg | NVIDIA Jetson AGX Orin 64 GB | No | No | without or with 3× GMSL2 |
| Workbench + Pro (recommended) | WidowX Pro | 4 kg | NVIDIA Jetson AGX Orin 64 GB | No | No | without or with 3× GMSL2 |
| Workbench + Heavy | WidowX Heavy | 8 kg | NVIDIA Jetson AGX Orin 64 GB | No | No | without or with 3× GMSL2 |
| Workbench Complete + Core | WidowX Core | 2 kg | NVIDIA Jetson AGX Orin 64 GB | Yes | Yes | without or with 3× GMSL2 |
| Workbench Complete + Pro (recommended) | WidowX Pro | 4 kg | NVIDIA Jetson AGX Orin 64 GB | Yes | Yes | without or with 3× GMSL2 |
| Workbench Complete + Heavy | WidowX Heavy | 8 kg | NVIDIA Jetson AGX Orin 64 GB | Yes | Yes | without or with 3× GMSL2 |
Technical data
WidowX follower arms
| WidowX Core | WidowX Pro | WidowX Heavy | |
|---|---|---|---|
| Degrees of freedom | 6 | 6 | 6 |
| Payload | 2 kg | 4 kg | 8 kg |
| Reach | 700 mm | 700 mm | 1,500 mm |
| Application profile | Cost-effective research arm | All-round arm for research, data collection and application development | Higher payload and larger workspace |
Common features of all WidowX arms:
- Integrated Trossen iNerve controller in the base running at over 600 Hz, compensating for the arm's own weight, friction and motion dynamics
- CNC-machined metal structure, no bent sheet metal
- Industrial-grade slewing bearing
- Rack-and-pinion gripper with straight-line jaws and virtually no play
- Integrated touchscreen with live diagnostics
- Locking M12 connectors, Industrial Ethernet (no USB)
- GPIO connectors for emergency stop and hardware synchronization
- Sealed connectors, sheathed and user-replaceable cables
- Torx fasteners for repeated servicing
Workbench station
- Design: portable bimanual station on a machined metal plate with handles
- Mounting: clamps for stable work surfaces
- Computer: NVIDIA Jetson AGX Orin 64 GB
- Camera system: GMSL2, scene camera on a post with fixed height and angle
- Software: open-source Trossen SDK
Glide leader arm (Workbench Complete)
- 6 degrees of freedom
- Reach: 0.687 m
- Lightweight carbon fiber construction with passive spring-and-cam counterbalance
- Passive joints with high-resolution encoders and dual ball bearings
- Programmable buttons and touchscreen
- Wired Ethernet
- GPIO hardware synchronization
- Global remote teleoperation via Trossen Cloud
- Control in joint space (kinematically similar arms) and Cartesian space (kinematically dissimilar robots)
Cockpit operator station (Workbench Complete)
- Holds two Glide leader arms
- Height-adjustable, mobile with lockable casters
- Battery: 10 Ah, approx. 8 hours runtime
- 10" touchscreen
- Wired Ethernet or Wi-Fi
- Built-in Trossen Data Collection App
- Global remote teleoperation via Trossen Cloud
- Machined mounting plate, powder-coated steel frame, anodized aluminum brackets
Scope of delivery
Workbench (all arm variants)
- Machined metal base plate with integrated handles
- Clamps for securing to the work table
- 2× WidowX follower arm (Core, Pro or Heavy), each with gripper, power supply and cables
- Camera post for the scene camera
- NVIDIA Jetson AGX Orin 64 GB, mounted on the station
- Power distribution and networking, mounted on the station
- User interface
- Open-source Trossen SDK with training examples and preconfigured workflows
- Optional: 3× GMSL2 camera
Workbench Complete (all arm variants) – additionally
- 2× Glide leader arm (left and right)
- Cockpit operator station
Reviews
There are no reviews yet.

