



TrossenRobotics Rivet
- SKU: MBS-TR-22
- Category: Robot Arms
-
Manufacturers:

TrossenRobotics Rivet
- Everything in one system: swerve drive, lift axis, two WidowX arms, compute and cameras integrated at the factory
- Mobile and flexible: omnidirectional up to 1.6 m/s, Z lift axis with 1.2 m of travel
- All-day operation: swappable 60 Ah battery, arm variants from 2 to 8 kg payload
Description
Trossen Rivet – Mobile Dual-Arm Platform for Physical AI
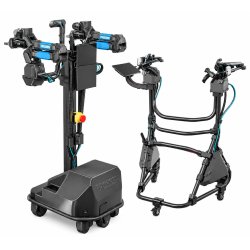
The Trossen Rivet is a configurable mobile manipulation platform that brings everything essential together in a single system: an omnidirectional swerve drive, a vertical lift axis, onboard power and compute, perception, and two WidowX robotic arms. Data collection, training, evaluation and deployment of Physical AI models all run on the same hardware – with no rebuild between project phases.
What sets it apart from stationary setups is the workspace. A tabletop rig always collects data in the same spot, under the same lighting and at the same height. The Rivet drives to where the task actually happens: shelves, workbenches, kitchen counters or lab stations. Its lift axis with 1.2 m of travel brings the arms down to floor level as well as up to table height and beyond. The result is more diverse training data – and models that perform better outside the lab.
The three-wheel swerve drive moves the platform in any direction without manoeuvring first, at up to 1.6 m/s. A swappable 60 Ah battery keeps the platform running for a full working day and can be exchanged without tools when the job takes longer.
Your Benefits at a Glance
- All in one system: drive base, lift axis, two arms, compute, cameras and battery integrated from the factory
- Omnidirectional mobility: three-wheel swerve drive, up to 1.6 m/s, movement in any direction without manoeuvring
- Large vertical workspace: screw-driven Z lift axis with 1.2 m of travel
- All-day operation: user-swappable 60 Ah battery
- Three arm variants: WidowX Core, Pro or Heavy – from 2 to 8 kg payload
- Safety on board: 360° bumper and emergency stop via GPIO
- End-to-end workflow: collect, train, evaluate and deploy on the same platform
Technical data
| Product type | Indoor mobile manipulation platform |
| Manipulators | Two WidowX arms – Core, Pro or Heavy; matching or mixed pair |
| Payload per arm | 2 kg Core / 4 kg Pro / 8 kg Heavy |
| Drive | Three swerve modules, holonomic |
| Top speed | 0.8 m/s |
| Vertical axis | Screw-driven linear rail, 890 mm travel |
| Battery | 24 V, 60 Ah, user-swappable |
| Runtime | approx. 5 hours |
| Charging | External charger |
| Auxiliary power | 24 V and 12 V breakout |
| Compute | NVIDIA Jetson AGX Orin 64 GB |
| Perception | Front-mounted 2D RPLiDAR; GMSL2 camera positions (cameras sold separately) |
| Interfaces | USB-C and Ethernet (RJ45) ports on the outside of the platform, wired to the onboard PC |
| Local interface | Touchscreen on the platform |
| Safety | Emergency stop; safety bumper |
| Mass | approx. 75 kg |
| Base footprint | 560 × 660 mm |
| Overall dimensions | 710 × 835 × 1,530 mm (W × L × H) |
| Software | Open-source Trossen SDK; ROS 2 interfaces; LeRobot |
Choosing the Manipulator
The Rivet ships with two WidowX arms. Which variant fits is determined by the payload and reach your task requires:
| Variant | Reach | Payload | Suited for |
| WidowX Core | 700 mm | 2 kg | light objects, entry into data collection |
| WidowX Pro | 700 mm | 4 kg | typical everyday handling tasks |
| WidowX Heavy | 1,400 mm | 8 kg | heavy loads and long reach |
All WidowX variants come with a touchscreen, an integrated industrial controller, an all-metal industrial frame, Delta and FlexGrip end effectors, integrated cable management and custom commercial-grade wiring.
Typical Applications
- Data collection for imitation learning and vision-language-action models
- Evaluation of trained policies in real working environments
- Mobile manipulation in lab, logistics and household scenarios
- Bimanual handling, order picking and machine tending
- Research and teaching in Physical AI and Embodied AI
Matching Accessories
For teleoperated data collection, the Rivet pairs ideally with the Trossen Cockpit: an ergonomic, height-adjustable teleoperation station with two Glide leader arms that control any manipulator in joint space and Cartesian space – on site or remotely via Trossen Cloud.
Scope of delivery
- Mobile base
- Vertical axis
- Battery and charger
- Onboard computer NVIDIA Jetson AGX Orin 64 GB
- 2D RPLiDAR
- Touchscreen
- Arm mounts
Note: WidowX arms (Core, Pro or Heavy) and cameras are not included and are configured separately.
Reviews
There are no reviews yet.

