



Description
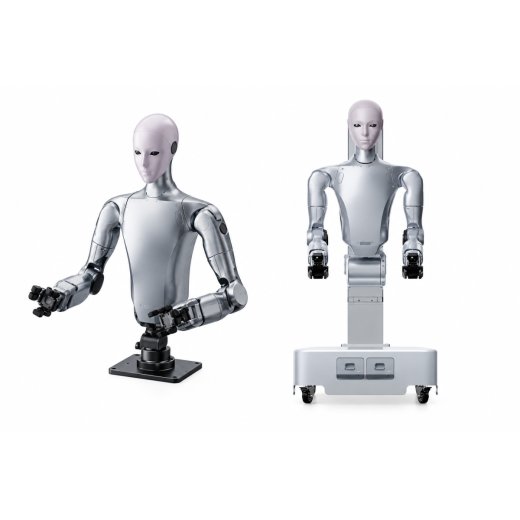
Unitree H2-D – dual-arm humanoid robot on a lifting column
The H2-D combines the humanoid upper body of the H2 family with a lifting column instead of legs. Two arms with seven degrees of freedom each, a movable torso and a head with a binocular camera sit on a column that raises the entire upper body by 0.5 m – from 1,200 mm overall height in the lowered position to 1,700 mm extended. The robot thus reaches both floor level and upper shelves, without the balance problems of a bipedal system.
For manipulation research, teleoperation and data collection this is often the more practical route: the compute that goes into gait control on a humanoid is fully available here for perception and grasping. Both configurations support secondary development and ship with two onboard computers that can be expanded by up to two further modules.
Two configurations to choose from
- H2-D Standard: stationary base that rotates about its vertical axis but does not travel. The column adds two degrees of freedom (lift and ±90° rotation). Powered by an external supply for continuous operation.
- H2-D Flagship: mobile platform at up to 1.5 m/s with differential drive and 360° rotation on the spot. With LiDAR, depth camera, ultrasonic and collision sensing in the base, a swappable battery for around 5 hours of runtime, and a charging station.
Caution: run gestures only with the hands removed
The robot’s pre-programmed gestures and motion sequences were trained without dexterous hands fitted. As long as the robot has no knowledge that hands are attached, its motion planning does not account for their additional length and mass – the robot can strike itself and damage the hands in the process.
Therefore run gestures and pre-programmed motion sequences only with the hands removed. Damage caused by running such sequences with the hands fitted is excluded from warranty. Contact us if you need motion sequences for operation with hands attached.
Technical data
| Feature | H2-D Standard | H2-D Flagship |
| Dimensions | 1,200 × 576 × 620 mm retracted, 1,700 mm extended | 1,200 × 576 × 620 mm retracted, 1,700 mm extended |
| Weight | 135 kg incl. battery | 135 kg incl. battery |
| Degrees of freedom | 19 without end effector · 21 with gripper arms 7×2, torso 1, head 2, column 2 |
20 without end effector · 22 with gripper arms 7×2, torso 1, head 2, column 1, base 2 |
| Payload per arm | approx. 7 kg | approx. 7 kg |
| Reach per arm | approx. 0.62 m with two-finger gripper | approx. 0.62 m with two-finger gripper |
| Waist motion | pitch 0° to 115° | pitch 0° to 115° |
| Lifting column | 0.5 m stroke, max. approx. 200 mm/s, plus ±90° rotation | 0.5 m stroke, max. approx. 200 mm/s |
| Base | stationary, rotates about the vertical axis on the spot | mobile up to 1.5 m/s, servo differential drive, 360° on the spot, turning diameter approx. 0.75 m |
| Base sensors | – | 1× LiDAR, 1× depth camera, 2× collision sensor, 2× ultrasonic sensor |
| Cameras | 1× binocular wide-angle camera in the head, 2× HD wrist camera | 1× binocular wide-angle camera in the head, 2× HD wrist camera |
| Base compute | PC1 Intel Core i5 (platform), PC2 Intel Core i7 (development) | PC1 Intel Core i5 (platform), PC2 Intel Core i7 (development) |
| Expansion | PC3 slot: NVIDIA Jetson Thor (2,070 TFLOPS) PC4 slot: Intel Core i7 or Jetson Orin NX (100 TOPS) |
PC3 slot: NVIDIA Jetson Thor (2,070 TFLOPS) PC4 slot: Intel Core i7 or Jetson Orin NX (100 TOPS) |
| Wireless | WiFi 6, Bluetooth 5.2 | WiFi 6, Bluetooth 5.2 |
| Power | external power supply, 7×24 h continuous operation; 2 swappable batteries in the base act only as buffer storage (Confirmation from the manufacturer on the series configuration is still outstanding.) | swappable 48 V / 30 Ah battery (1.44 kWh) in the base, approx. 5 h runtime, battery swap or automatic docking |
| Software | secondary development supported, OTA updates | secondary development supported, OTA updates |
| Warranty | 12 months | 12 months |
Hand variants A to M
The letter variant determines the end effector only – the rest of the robot is identical across all versions. Each hand is supplied as a pair and comes with an RGB wrist camera (1920 × 1080, FOV D 130° / H 120° / V 81°).
| Variant | End effector | Tactile | DOF per hand | Grip force |
| A | Dex1-1 two-finger gripper | – | 1 | 5–120 N adjustable |
| B | Dex3-1 three-finger hand | – | 7 | force-controlled |
| C | Dex3-1 three-finger hand | 33 sensors | 7 | force-controlled |
| D | Dex5-1 five-finger hand | – | 16 | 10 N fingertip |
| E | Dex5-1P five-finger hand | 94 pressure sensors | 16 | 10 N fingertip |
| F | BrainCo Revo 2 Basic | – | 6 | 50 N total, 15 N per finger |
| G | BrainCo Revo 2 Touch | pressure, friction, proximity | 6 | 50 N total, 15 N per finger |
| H | Inspire DFQ | – | 6 | 6 N thumb, 4 N fingers |
| I | Inspire E2 | 17 sensors, 0–30 N | 6 | 30 N thumb, 28 N fingers |
| J | BrainCo Revo 3 U21 | – | 21 | 70 N total, 20 N fingertip |
| K | BrainCo Revo 3 U21T | palm, 0.01 N | 21 | 70 N total, 20 N fingertip |
| L | BrainCo Revo 3 U21VT | visuo-tactile, from 130 µm | 21 | 70 N total, 20 N fingertip |
| M | WUJI Hand 2 | – | 20 | ≥ 15 N fingertip |
Typical applications
- Manipulation research with two arms and interchangeable end effectors
- Teleoperation and data collection for imitation learning
- Order picking and handling at workstations of varying height
- Machine tending and laboratory automation
- Demonstrations and teaching where a bipedal robot would be too delicate
Scope of delivery
H2-D Standard
- 1× H2-D Standard in the selected hand variant, incl. pair of end effectors with wrist cameras
- 1× Handheld remote
- 2× Swappable battery in the base
- External power supply
H2-D Flagship
- 1× H2-D Flagship in the selected hand variant, incl. pair of end effectors with wrist cameras
- 1× Handheld remote
- 1× Visualisation laptop (15.6", Intel Core Ultra 7, 32 GB, 1 TB, Ubuntu 22.04)
- 1× Swappable 48 V / 30 Ah battery
- 1× Charging station
Reviews
There are no reviews yet.

