


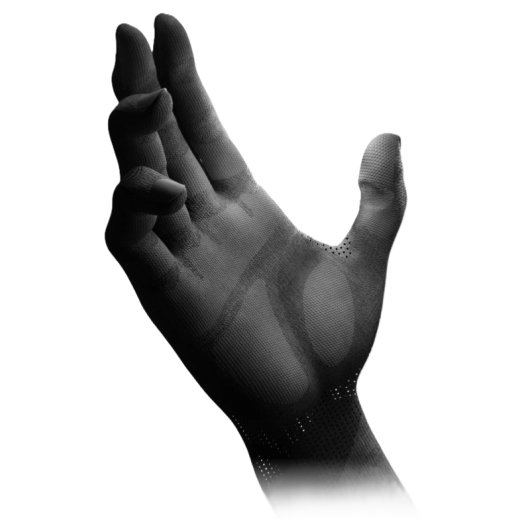
Wuji Hand 2
- SKU: MBS-G-54
- Category: Gripper
-
Manufacturers:

Wuji Hand 2
- 20 active degrees of freedom (DOF)
- Direct drive, with feedback capability
- Force/torque sensors in the fingertips
- 1000 Hz control rate
Description
The Wuji Hand 2 is the second generation of Wuji Technology's fully direct-driven, biomimetic dexterous hand. With 20 active degrees of freedom (4 per finger), an anthropomorphic form factor and full thumb opposition, it combines human-like mobility with precise force control. The back-drivable direct-drive joints (FOC vector control), together with the MIT force-position hybrid control, provide high force transparency at the joint level, while the three-layer structure of skeleton, biomimetic soft body and replaceable protective skin reproduces the mechanics of the human hand. Thanks to Ethernet connectivity, a factory-standard wrist flange and a software ecosystem comprising the Wuji SDK, Wuji Studio and simulation models (URDF, MJCF, USD) for MuJoCo and Isaac Sim, the Wuji Hand 2 is a versatile platform for manipulation research, embodied AI and teleoperation.
Note: The Wuji Hand 2 is currently a Beta 1 prototype. Specifications and behavior are preliminary and may change before series production. Beta 1 makes no guarantees regarding lifetime, durability or shock resistance; prolonged operation at full load should be avoided. The external interface (currently XT30 + RJ45) will change in later versions – please allow room in your integration design.
Features
- 20 active degrees of freedom (4 per finger) with full thumb opposition and lateral abduction
- Fully direct-driven, back-drivable joints with FOC vector control for high force transparency
- Serial rotary direct-drive joints with no nonlinear kinematic coupling
- 1000 Hz control frequency across all 20 axes with MIT force-position hybrid control
- Three-layer structure: mechanical skeleton, biomimetic soft body and replaceable protective skin
- Factory-standard wrist flange incl. mounting drawings
- Software ecosystem: Wuji SDK (Python) & Wuji Studio plus simulation models (URDF, MJCF, USD; skeleton) for MuJoCo and Isaac Sim
- Teleoperation via Wuji Glove (demo)
- Compact design at just 745 g (excluding cables)
Technical Data
| Active degrees of freedom | 20 DOF (4 per finger) |
| Finger configuration | Full opposition, lateral abduction |
| Kinematics | Serial rotary direct-drive joints, back-drivable, no nonlinear coupling |
| Drive control | FOC vector control |
| Control frequency | 1000 Hz × 20 axes |
| Control mode | MIT force-position hybrid control |
| Communication | Ethernet, RJ45 (100BASE-TX) |
| Operating voltage | 12 V DC |
| Power adapter | 12 V / 20 A (included) |
| Weight | 745 ± 10 g (with soft body, excl. cables) |
| Dimensions | 180 × 80 × 40 mm |
| Min. grasp diameter | 0 mm |
| Software | Wuji SDK (Python), Wuji Studio, simulation models URDF / MJCF / USD (MuJoCo, Isaac Sim) |
| Teleoperation | Wuji Glove (demo) |
| Note | Specifications reflect the current Beta 1 status and are subject to ongoing development |
Scope of Delivery
- 1× Wuji Hand 2 dexterous hand (right or left)
- 1× power adapter 12 V / 20 A
- 1× AC power cable
- 1× RJ45 cable (shielded, Cat5e, 2 m)
- 1× XT30 extension cable (14 AWG, 2 m)
- 1× adapter mount
- 1× adapter flange
Reviews
There are no reviews yet.

