


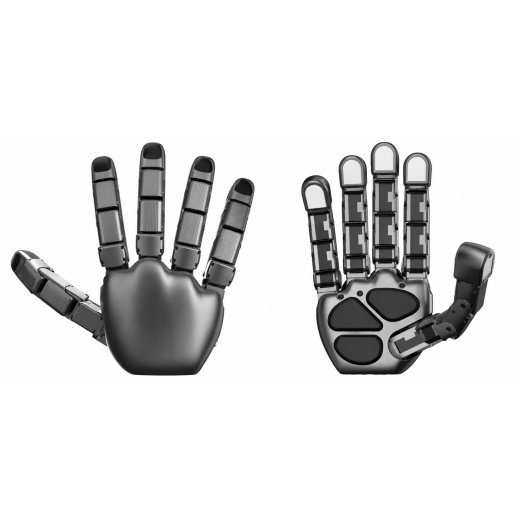
Allegro Hand V6
- SKU: MBS-G-55
- Category: Gripper
-
Manufacturers:

Allegro Hand V6
- 20 active degrees of freedom: five fingers with four driven joints each, abduction 97° to 130°
- 15 kg payload at 1.24 kg of its own weight: 0.92 N·m per joint, 0.15 s per 60°
- Two sensor variants: V6 F with 18 pressure sensors, V6 V visuo-tactile – 500 Hz control over RS-485 or Ethernet
Description
V6 Dexterous Hand – five fingers, 20 active degrees of freedom
The V6 is an anthropomorphic robotic hand with five fingers and 20 actively driven joints – four per finger. It therefore covers most of the range of human grasp types, from a precision pinch with the fingertips to an enveloping power grasp. Spreading fingers with 97° to 130° of abduction and adduction also allow grip configurations that three-finger hands cannot achieve.
The ratio of weight to payload is notable: at 1.24 kg of its own weight, the hand carries up to 15 kg. This is made possible by DC motors with a 288.35:1 geared reduction and 0.92 N·m of stall torque per joint. A joint moves through 60 degrees in 0.15 seconds.
Control runs over RS-485 or Ethernet using Modbus RTU or TCP, or alternatively a manufacturer-specific RS-485 protocol. The control loop runs at 500 Hz, with a choice of position control or torque control with current feedback – the prerequisite for compliant grasping of delicate objects.
Two sensor variants to choose from
- V6 F – tactile: 18 omnidirectional pressure sensors distributed across the fingertips, the insides of the fingers and the palm. The denser coverage when contact detection and grip force control are what matter. A colour indicator at the fingertips makes the applied pressure immediately visible.
- V6 V – visuo-tactile: combines optical sensing with eight pressure sensors – one per fingertip and three in the palm. The choice for research into visuo-tactile perception, in-hand object recognition and slip detection.
Your advantages at a glance
- 20 active degrees of freedom: four per finger, no underactuated couplings
- 15 kg payload: at only 1.24 kg of its own weight
- Fine joint resolution: 0.088° nominal via potentiometer
- 500 Hz control rate: position control and torque control with current feedback
- Open interfaces: RS-485 and Ethernet, Modbus RTU and TCP
- Spreading fingers: abduction and adduction from 97° to 130°
Technical data
| Feature | V6 F | V6 V |
| Fingers | 5 | 5 |
| Degrees of freedom | 20 active (5 × 4) | 20 active (5 × 4) |
| Sensor type | pressure sensors | optical sensors and pressure sensors |
| Sensor count and location | 18 omnidirectional pressure sensors: 5 at the fingertips, 10 on the insides of the fingers, 3 in the palm | 8 sensors: 1 per fingertip, 3 in the palm |
| Pressure detection range | 260 to 1,260 hPa, resolution 1 hPa | 260 to 1,260 hPa, resolution 1 hPa |
| Fingertip colour indicator | blue below 1,050 hPa, green below 1,130 hPa, yellow below 1,170 hPa, red above | – |
| Sensor operating temperature | 0 to +60 °C | 0 to +60 °C |
| Actuation | DC motor, 288.35:1 gear ratio | DC motor, 288.35:1 gear ratio |
| Stall torque | 0.92 N·m | 0.92 N·m |
| Joint speed | 0.15 s per 60° | 0.15 s per 60° |
| Joint measurement | potentiometer, 0.088° nominal | potentiometer, 0.088° nominal |
| Maximum payload | 15 kg | 15 kg |
| Weight | 1.24 kg | 1.24 kg |
| Communication | RS-485, Ethernet; Modbus RTU and TCP, RS-485 custom; 500 Hz | RS-485, Ethernet; Modbus RTU and TCP, RS-485 custom; 500 Hz |
| Control methods | position control, torque control with current feedback | position control, torque control with current feedback |
| Power supply | 24 V DC, 5 A, 120 W | 24 V DC, 5 A, 120 W |
| Abduction / adduction | 97° to 130° | 97° to 130° |
Typical applications
- Research into manipulation and tactile perception
- Imitation learning and teleoperation with force feedback
- Handling of delicate or irregularly shaped objects
- End effector on robot arms and humanoid platforms
- Teaching and training in grasping mechanics and control engineering
Note on selection
The choice between V6 F and V6 V comes down to the application, not the sensor count: with 18 sensors, the F version gives denser contact coverage across the whole gripping surface, while the V version provides optical information at the point of contact.
| Item information | Value |
|---|---|
| Shipping weight: | 1,50 kg |
| Item weight: | 1,20 kg |
Reviews
There are no reviews yet.

