



Description
Feature / Model
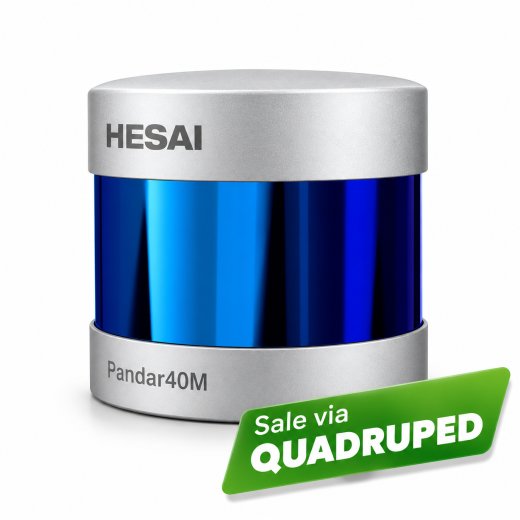
Pandar 40M
Pandar 40P
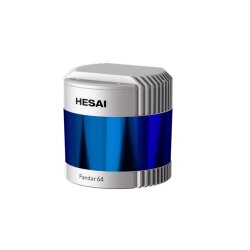
Pandar 64
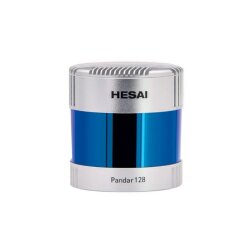
Pandar 128
Channels / Lasers
40
40
64
128
Scan Method
Mechanical rotation
Mechanical rotation
Mechanical rotation
Mechanical rotation
Range (10% reflectivity)
up to ~120 m
up to ~200 m
up to ~200 m
up to ~200 m
Horizontal FOV
360° horizontal
360° horizontal
360° horizontal
360° horizontal
Vertical FOV
~40° (–25° to +15°)
40° (–25° to +15°)
40° (–25° to +15°)
~40°
Resolution (H / V)
~0.2° horizontal / vertical per channel
0.2° horizontal / vertical ~0.33°
0.2° horizontal / vertical ~0.167°
Horizontal 0.1° / vertical ~0.125°
Point Cloud Rate
Depends on scan frequency and model
Up to 720,000 pts/s (single return), 1,440,000 pts/s (dual return)
Higher than 40P due to more channels
Up to 3,456,000 pts/s (single), 6,912,000 pts/s (dual)
Protection / Robustness
IP6K7
IP6K7
IP6K7
IP6K9K
Typical Use Cases
Compact LiDAR for medium range; vehicles, robotics, UAV, 3D mapping
Versatile use; automotive, robotics, mapping, autonomous driving
More layers → higher vertical resolution; mapping, autonomous systems
Highest resolution & point density; autonomous driving, complex 3D environments
Reviews
There are no reviews yet.


