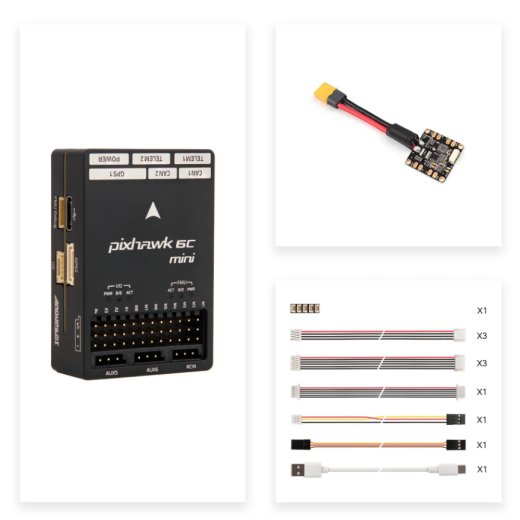
Holybro Pixhawk 6C Mini PM06, Ohne GPS, FC Model A
- SKU: MBS-ENTB-87-04
- GTIN: 0658917504991
- HAN: 20201
- Category: Pixhawk
-
Manufacturers:
Pixhawk 6C Mini
- High performance processor STM32H743 with more computing power and RAM
- New cost-efficient design with small form factor
- IMU redundancy with sensor technology from Bosch and InvenSense
- Integrated vibration isolation system
- Integrated heating resistors for optimal IMU operating temperature
Description
This set combines the compact flight controller Holybro Pixhawk 6C Mini (Model-A, current revision) with the PM06 14S Power Module – a ready-to-use basis for building autonomous vehicles with PX4 or ArduPilot.
The Pixhawk 6C Mini is based on the Pixhawk FMUv6C Open Standard and uses the same STM32H743 microprocessor and sensors as the Pixhawk 6C, but in a compact Mini form factor with a built-in PWM header. Inside works an STM32H743 (Arm Cortex-M7, up to 480 MHz, 2 MB flash, 1 MB RAM) with sensor technology from Bosch and InvenSense, IMU redundancy, vibration isolation and temperature-controlled IMUs. The current Model-A revision provides a more stable PWM signal under load.
The PM06 (V2, 14S) supplies the flight controller with clean 5.2 V and provides battery-voltage and current-consumption measurements via an analog 6-pin JST-GH signal. It also integrates power distribution for four ESCs and comes with pre-soldered wires, capacitor and XT60 connector.
Technical specifications – Pixhawk 6C Mini (Model-A, revision)
Processors & sensors
| FMU processor | STM32H743 – 32-bit Arm Cortex-M7, 480 MHz, 2 MB flash, 1 MB SRAM |
| IO processor | STM32F103 – 32-bit Arm Cortex-M3, 72 MHz, 64 KB SRAM |
| Accelerometer/gyro | ICM-42688-P and BMI088 |
| Magnetometer | IST8310 |
| Barometer | MS5611 |
Electrical & mechanical
| Max. input voltage | 6 V |
| USB input voltage | 4.75–5.25 V |
| Servo rail input | 0–36 V |
| Current limit (each combined) | Telem1 & GPS2: 1.5 A / other ports: 1.5 A |
| Operating temperature | -40 to 85 °C |
| Dimensions (Model-A, revision) | 54.3 × 39 × 17.5 mm |
| Weight (Model-A, revision) | 42.4 g |
| Standard / firmware | Pixhawk FMUv6C Open & Connector Standard / PX4, ArduPilot |
Technical specifications – PM06 (V2, 14S) Power Module
| Input voltage | 2S–14S |
| Continuous current (PCB) | 70 A |
| Peak current (PCB) | 120 A (< 60 s) |
| Output (BEC) | 5.2 V, max. 3 A |
| Max. output power | 18 W |
| Data output | analog, 6-pin JST-GH |
| Power distribution | integrated for 4 ESCs; XT60 connector + 12 AWG wire (30 A cont. / 60 A burst) |
| Dimensions / mounting hole | 35 × 35 × 5 mm / 30.5 × 30.5 mm |
| Weight | 24 g |
Scope of delivery
- 1× Holybro Pixhawk 6C Mini flight controller (Model-A, current revision)
- 1× PM06 14S Power Module (V2)
- 1× cable set
| Item information | Value |
|---|---|
| Shipping weight: | 0,20 kg |
| Item weight: | 0,07 kg |
Reviews
There are no reviews yet.


Telemetry Radio Set V3
- 433MHz
- > 300m Range
- Automatic detection with ArduPilo & DroneCode
- easy start-up with Pixhawk 4
Please note that without the appropriate radio operator license, the transmission power must be throttled to 25mW.